OUR WORK
Projects
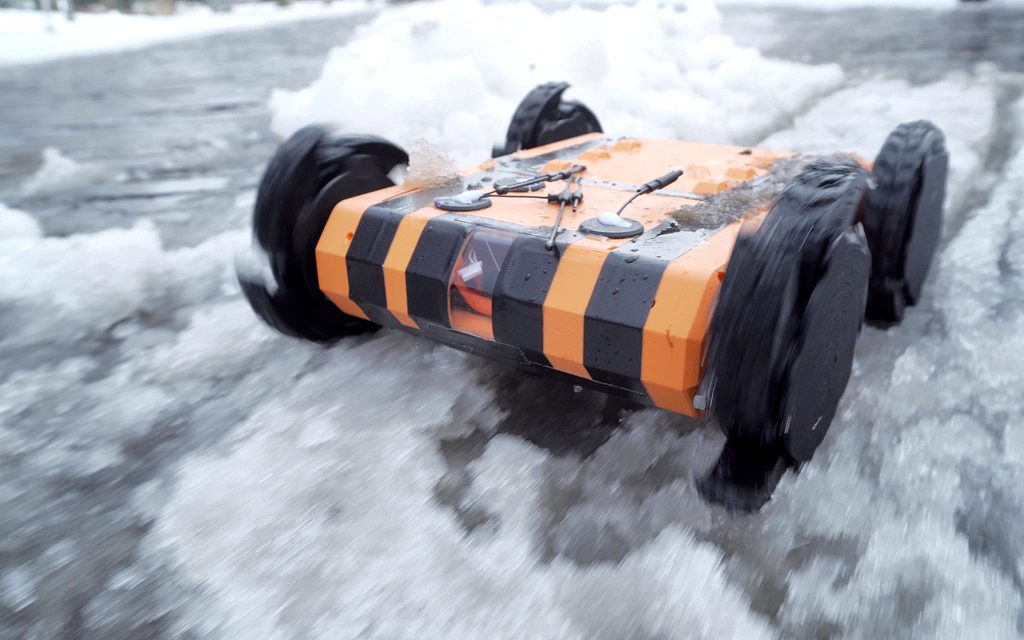
The OUTDOOR-UGV started with a straightforward challenge: build a capable unmanned ground vehicle that is fully 3D-printable, affordable, easy to manufacture and easy to repair. We designed the vehicle around standardized components and developed the body specifically for efficient additive manufacturing. The project led to numerous discoveries around lightweight structural design, material efficiency and modular assembly. The result is a platform designed to be practical both inside and outside the workshop, because a robot that looks great but is impossible to repair isn't that useful.
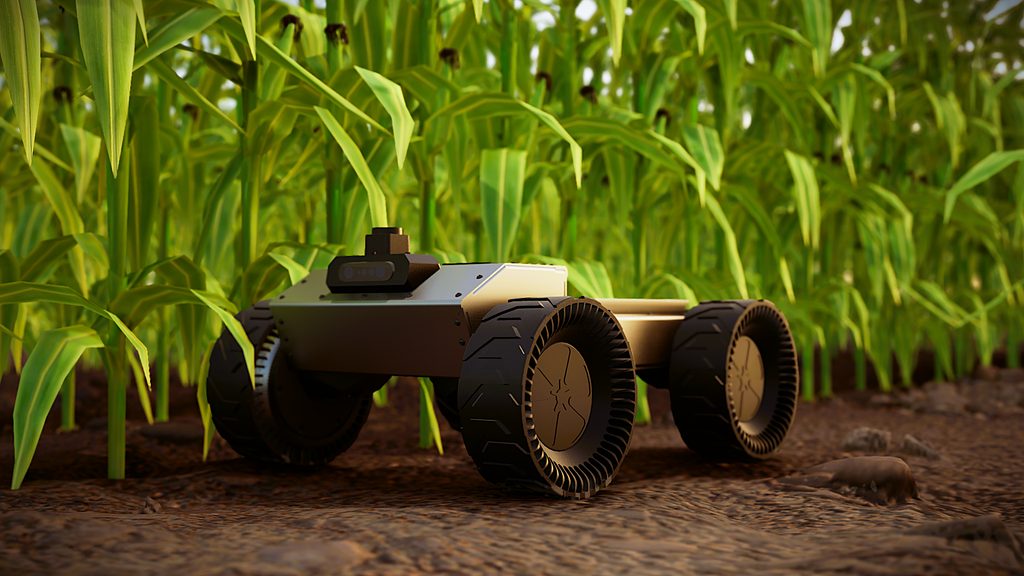
FIELDSENSE grew from the OUTDOOR-UGV project. While exploring potential applications for a low-cost, easy-to-manufacture robotic platform, we saw an opportunity in small-scale agriculture. Many agricultural insights depend on crop and environmental data, but collecting detailed information across a field can still be time-consuming and expensive. FIELDSENSE is designed to navigate between crop rows and collect localized data about plant health and environmental conditions. By bringing the robot closer to the crops, we aim to provide more detailed insights for precision agriculture, one row at a time.
GOT SOMETHING SIMILAR IN MIND?